Modules
Four families. One interface.
Swap a module, not the robot.
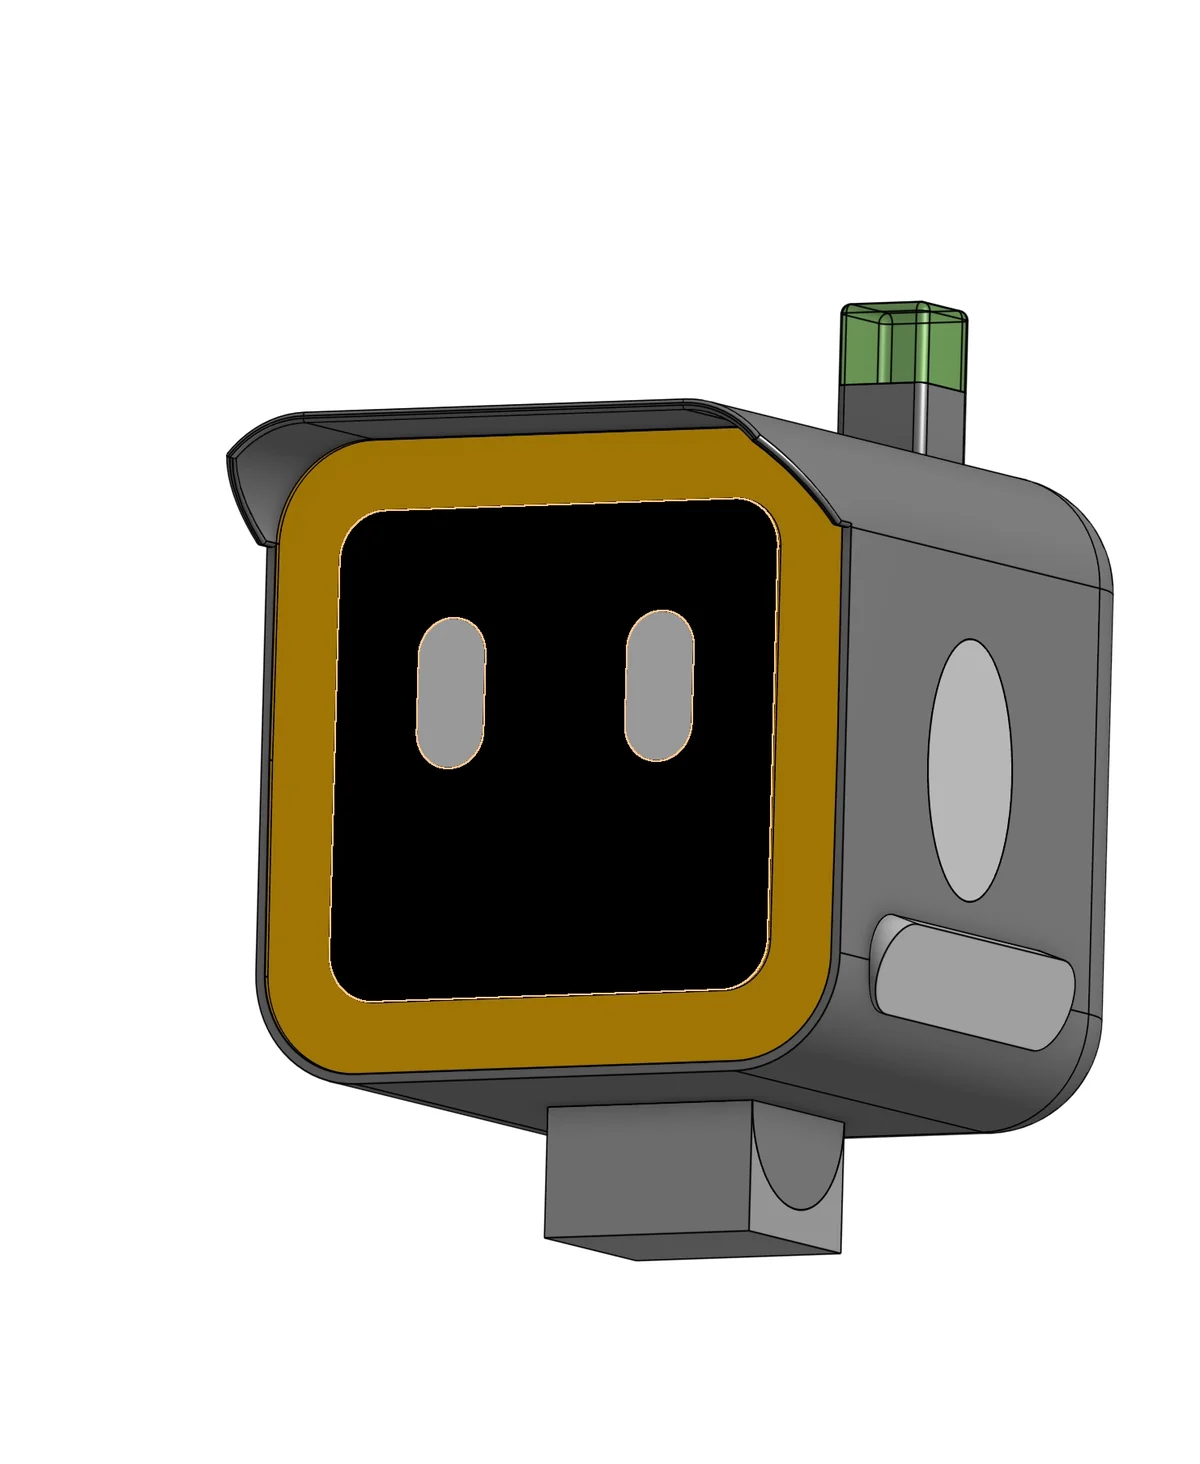 Module 01 · Head
Module 01
Head & interface
Face display, light ring, depth camera, speaker and microphone in one housing. The head is the robot's eyes and its way of talking to people.
- Display
- [—]
- Depth camera
- [—]
- Audio
- Speaker + mic
- Status light
- Top LED + ring
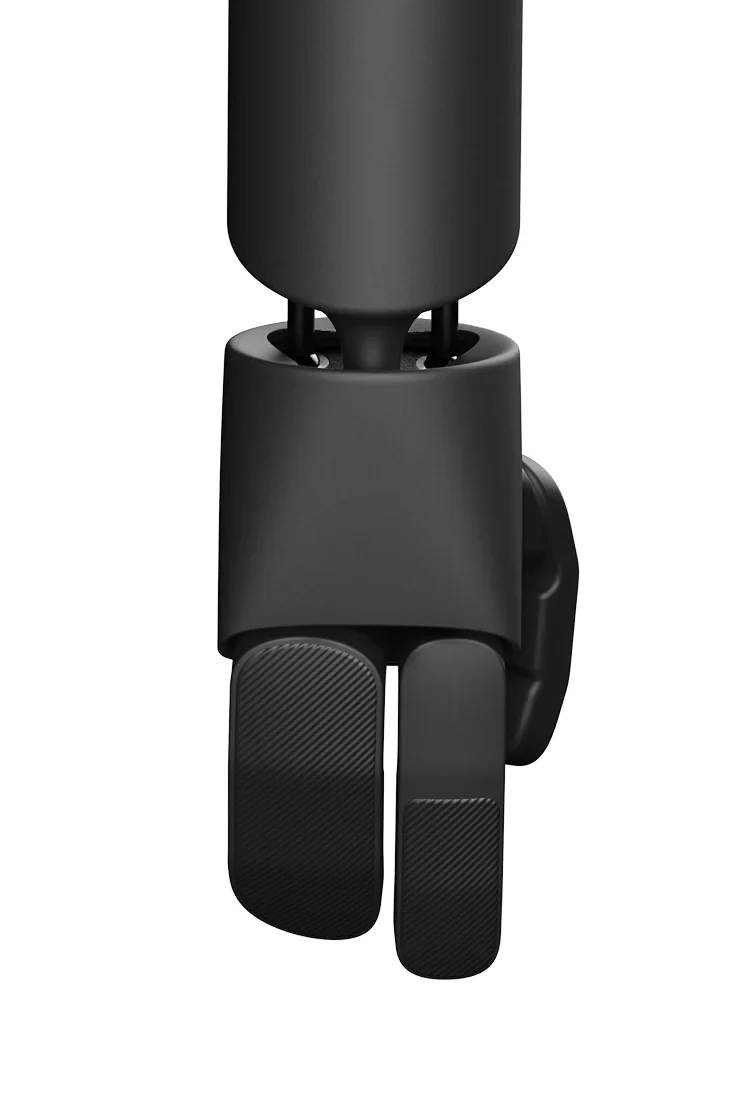 Module 02 · Hands
Module 02
Hands
Grippers and hands share one wrist interface. Pick the end effector that fits the task and change it in a shift break.
- Variants
- [—]
- Grip force
- [—] N
- Change time
- [—] min
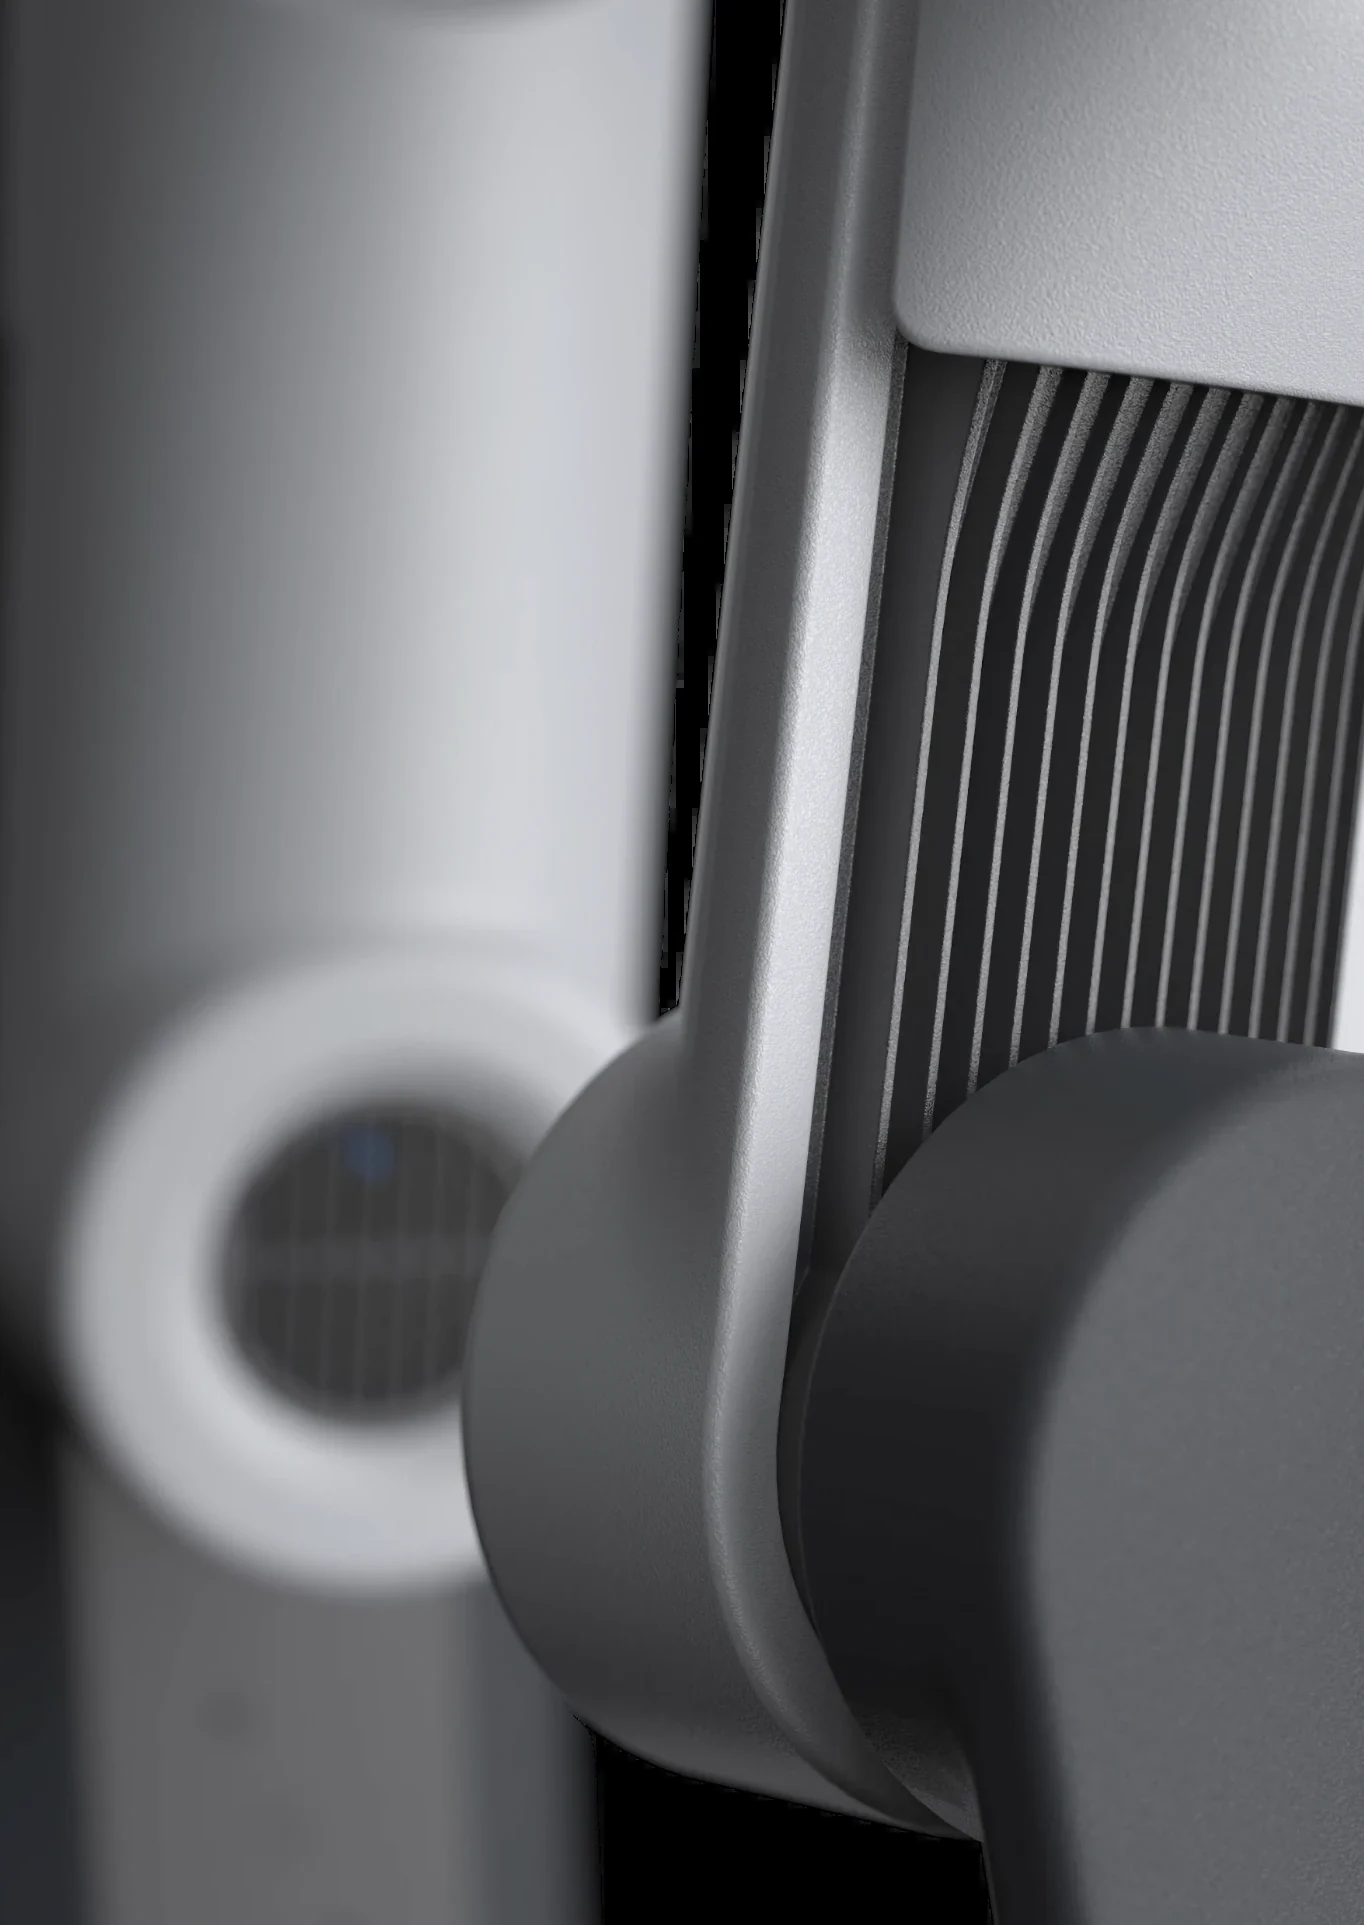 Module 03 · Limbs
Module 03
Limbs & joints
Arms and legs are built from a small set of identical actuator modules. Fewer part numbers mean simpler spare parts and faster repairs.
- Actuator types
- [—]
- Peak torque
- [—] Nm
- Swap time
- [—] min
Module 04
Energy
A 13S lithium-ion module with its own battery management. It sits in the torso and is reached from the side.
- Configuration
- 13S
- Capacity
- [—] Wh
- Charging time
- [—] h
The quick-connect interface.
One connection for mechanics, power and data – the part that makes the modules interchangeable.
Mechanical
[How the module locks and carries load.]
Power
[How power is passed through safely.]
Data
[How the robot recognises a new module.]